Side Project · Undergraduate Capstone, 2021
Autonomous Water-Cleaning Robot for Low-Clearance Spaces
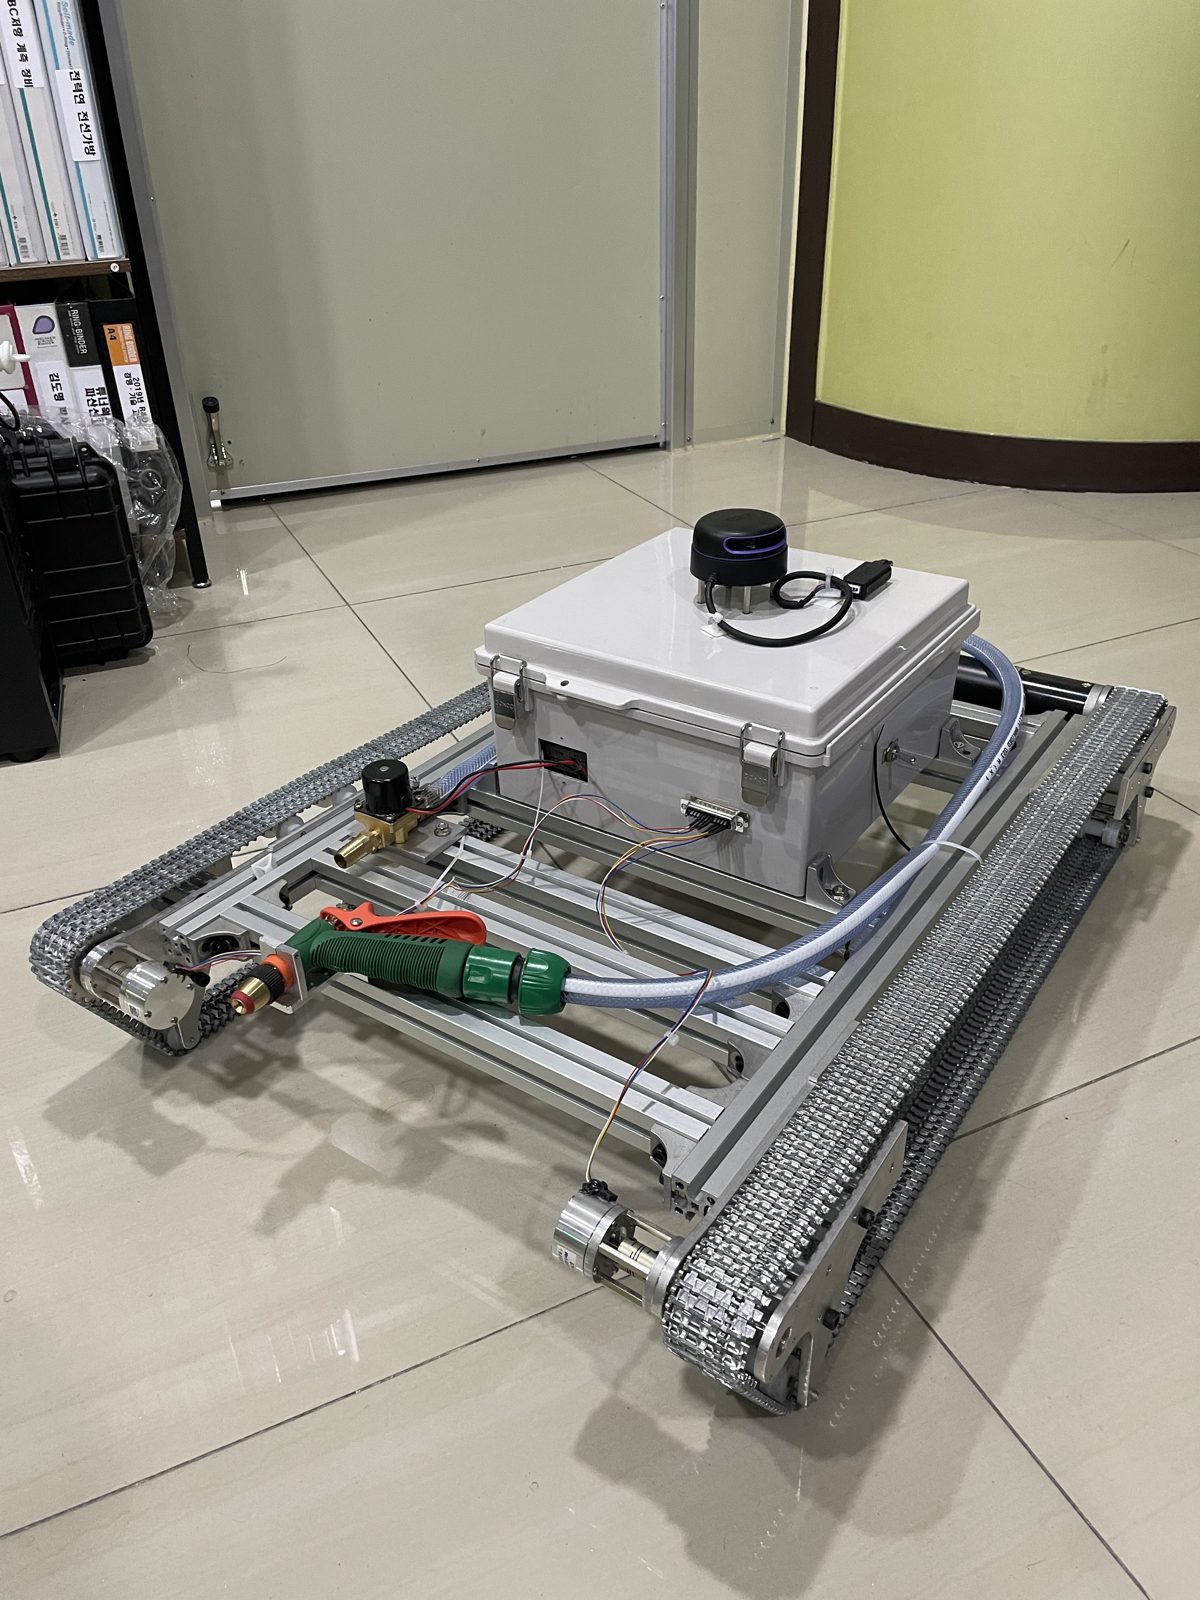
Spaces too low for a person to enter are hard to clean by hand. This tracked robot maps such a space with a 2D LiDAR, explores it on its own, and sprays water as it drives.
Overview
Our two-person team built this robot from scratch. We designed the tracked aluminium frame in CAD and machined it on a CNC, then put the battery, a Jetson Nano, the motor driver and a solenoid-valve water spray onto it. On the Jetson we set up ROS so the robot maps the space with a 2D LiDAR, explores it on its own and drives its motors over serial.
Build log